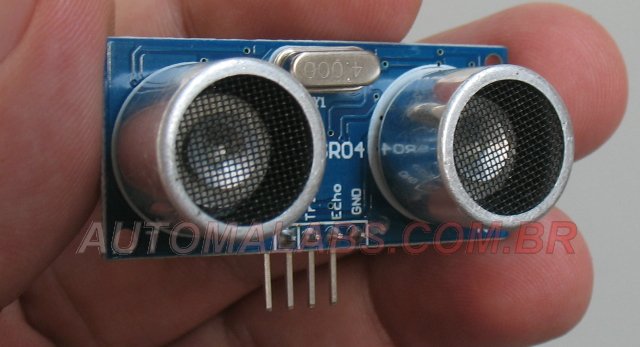
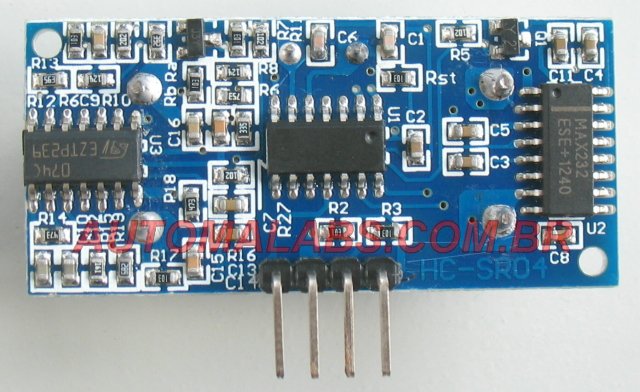
Este sensor não funciona se o shield Wiznet estiver plugado, mesmo que nenhuma biblioteca seja ativada.
sketch de teste
Requer Shield com keypad e display 1602
Exemplo testado com Arduino 1.05
// Jefferson Ryan - Automalabs.com.br
// Baseado em script de: luckylarry.co.uk
// Este sketech também demonstra o uso de Running Average.

#include <LiquidCrystal.h>
//Esta linha é específica para o display do shield com keypad
//se seu display for diferente você pode precisar mudar
LiquidCrystal lcd(8, 9, 4, 5, 6, 7);

// variables to take x number of readings and then average them
// to remove the jitter/noise from the SRF05 sonar readings
const int qtdeLeituras = 10;                   // number of readings to take/ items in the array
int leituras[qtdeLeituras];                    // stores the distance readings in an array
int indice = 0;                             // arrayIndex of the current item in the array
int total = 0;                                  // stores the cumlative total
int distanciaMedia = 0;                        // stores the average value

// setup pins and variables for SRF05 sonar device

int echoPin = 2;                                // SRF05 echo pin (digital 2)
int triggerPin = 3;                                // SRF05 trigger pin (digital 3)
unsigned long tempoPulso = 0;                    // stores the pulse in Micro Seconds
unsigned long distancia = 0;                     // variable for storing the distance (cm)

void setup() {
lcd.begin(16, 2);

lcd.clear();
pinMode(triggerPin, OUTPUT);                     // set init pin 3 as output
pinMode(echoPin, INPUT);                      // set echo pin 2 as input

// create array loop to iterate over every item in the array

for (int estaLeitura = 0; estaLeitura < qtdeLeituras; estaLeitura++) {
leituras[estaLeitura] = 0;
}

}

void loop() {

digitalWrite(triggerPin, HIGH);                    // send 10 microsecond pulse
delayMicroseconds(10);                  // wait 10 microseconds before turning off
digitalWrite(triggerPin, LOW);                     // stop sending the pulse
tempoPulso = pulseIn(echoPin, HIGH);             // Look for a return pulse, it should be high as the pulse goes low-high-low
distancia = tempoPulso/58;                        // Distance = pulse time / 58 to convert to cm.

total= total - leituras[indice];           // subtract the last distance
leituras[indice] = distancia;                // add distance reading to array
total= total + leituras[indice];            // add the reading to the total
indice = indice + 1;                    // go to the next item in the array

// Ao chegar ao fim da matriz, voltamos a preencher do inicio
if (indice >= qtdeLeituras)  {
indice = 0;
}

distanciaMedia = total / qtdeLeituras;      // calculate the average distance

String myString = String(distanciaMedia, DEC);
myString +=" cm";
char charBuf[10];
//apago o conteúdo do array. Sem isso as leituras ficam completamente malucas,
//porque "toCharArray" não faz isso.
memset(charBuf, 0, sizeof(charBuf));
myString.toCharArray(charBuf, 10);

lcd.clear();
lcd.setCursor(1, 0);
lcd.print(charBuf);

// Serial.println(averageDistance, DEC);
/*Se o delay for muito baixo (10, por exemplo), alguns exemplares
sensores irão apresentar alta instabilidade a curtas distâncias
*/
delay(50);

}
Leave a Comment